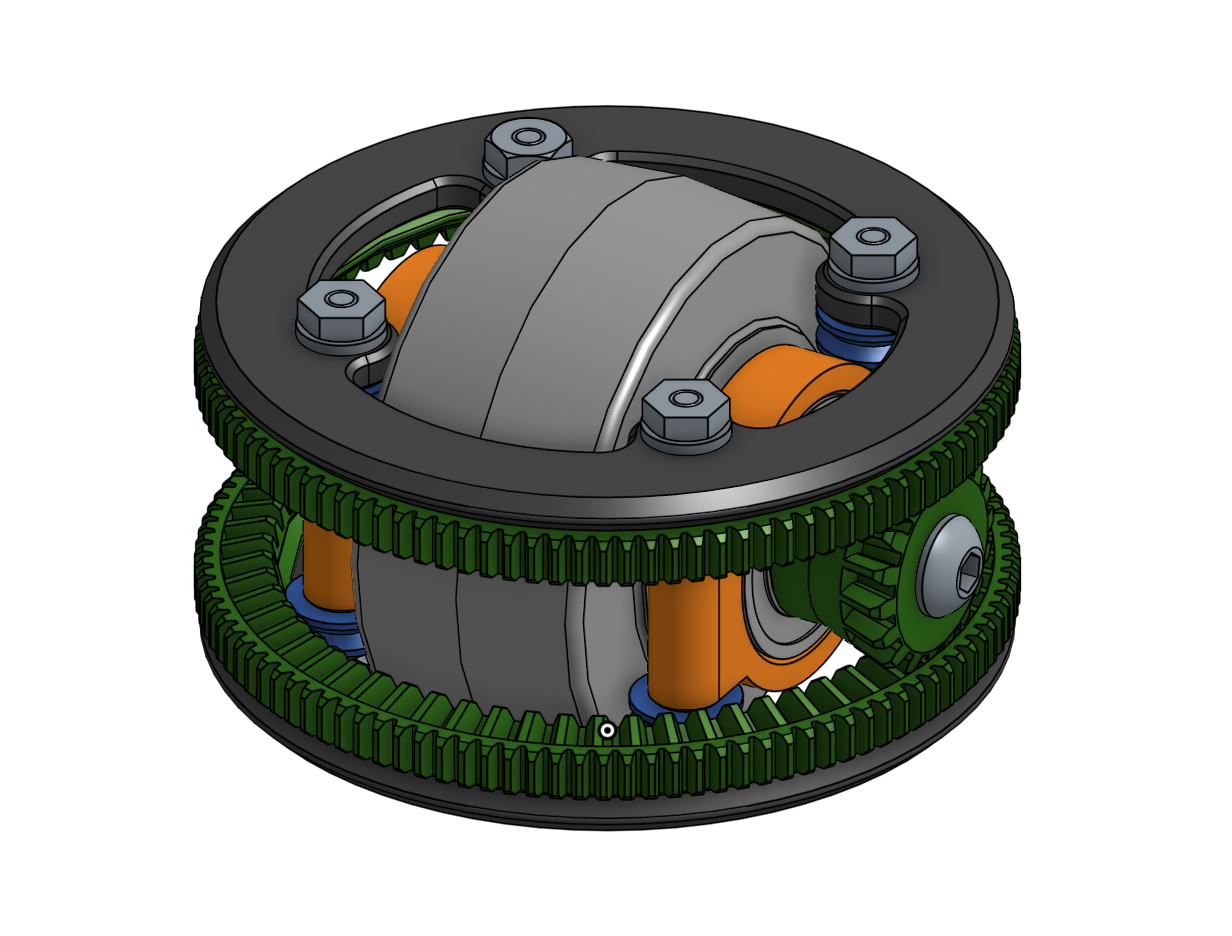
A swerve module lets a robot wheel both roll and change its steering direction. This design explores a differential arrangement that combines motor inputs to control those two motions, with the aim of sharing available power between driving and steering.
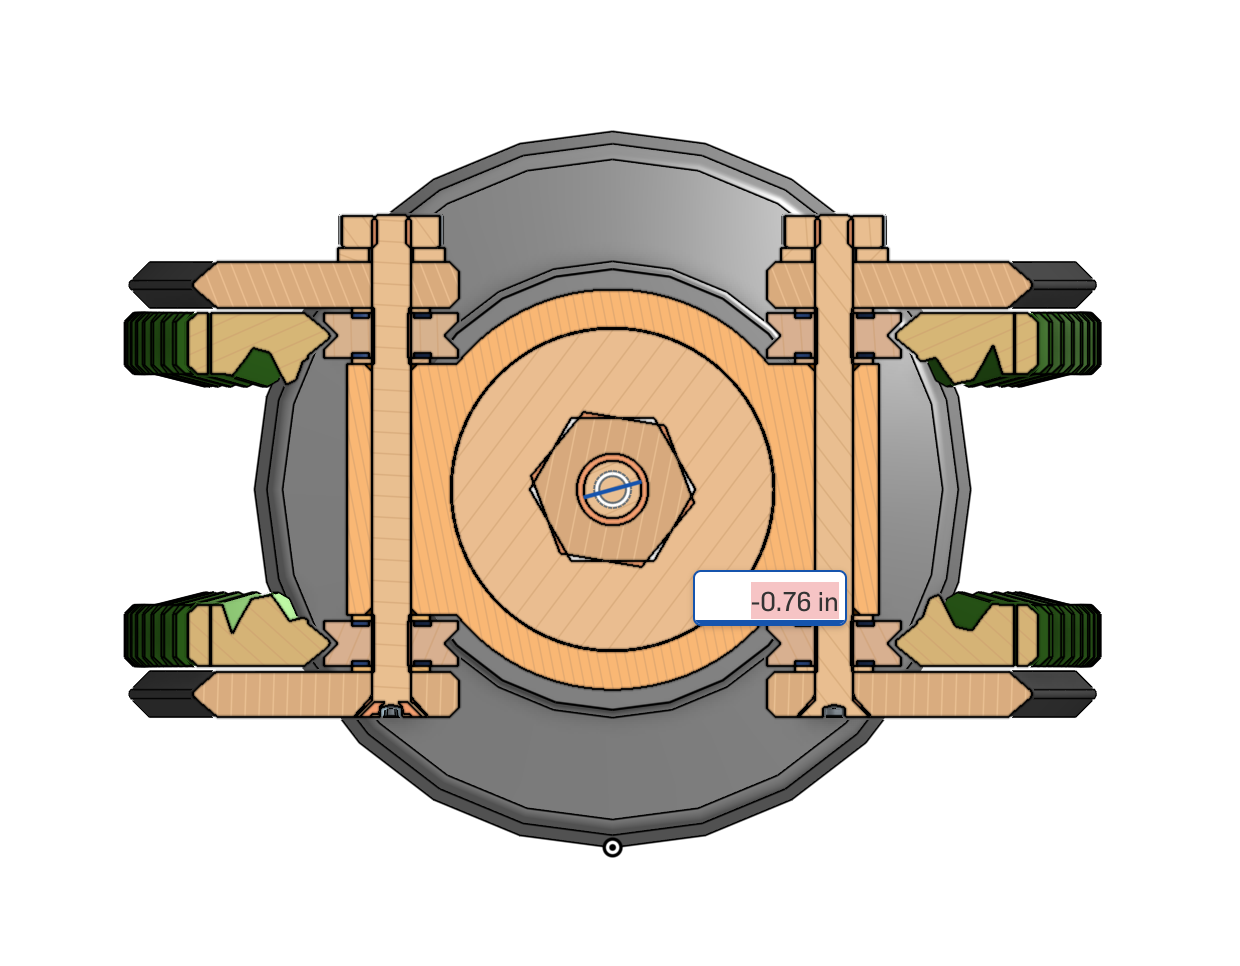
I developed a 3D-printable CAD assembly to explore the mechanism’s packaging and gear layout. The section view below shows how the gears and wheel fit together inside the module.
I shared the design on GrabCAD, where it passed 100 downloads. It is a module design; a complete drivebase and its control system remain next steps.
The next stage would be to build a drivebase, develop ROS-based control, and compare physical behavior with simulation. That would give me a way to evaluate steering response, drivetrain losses, and durability rather than judge the design from CAD alone.